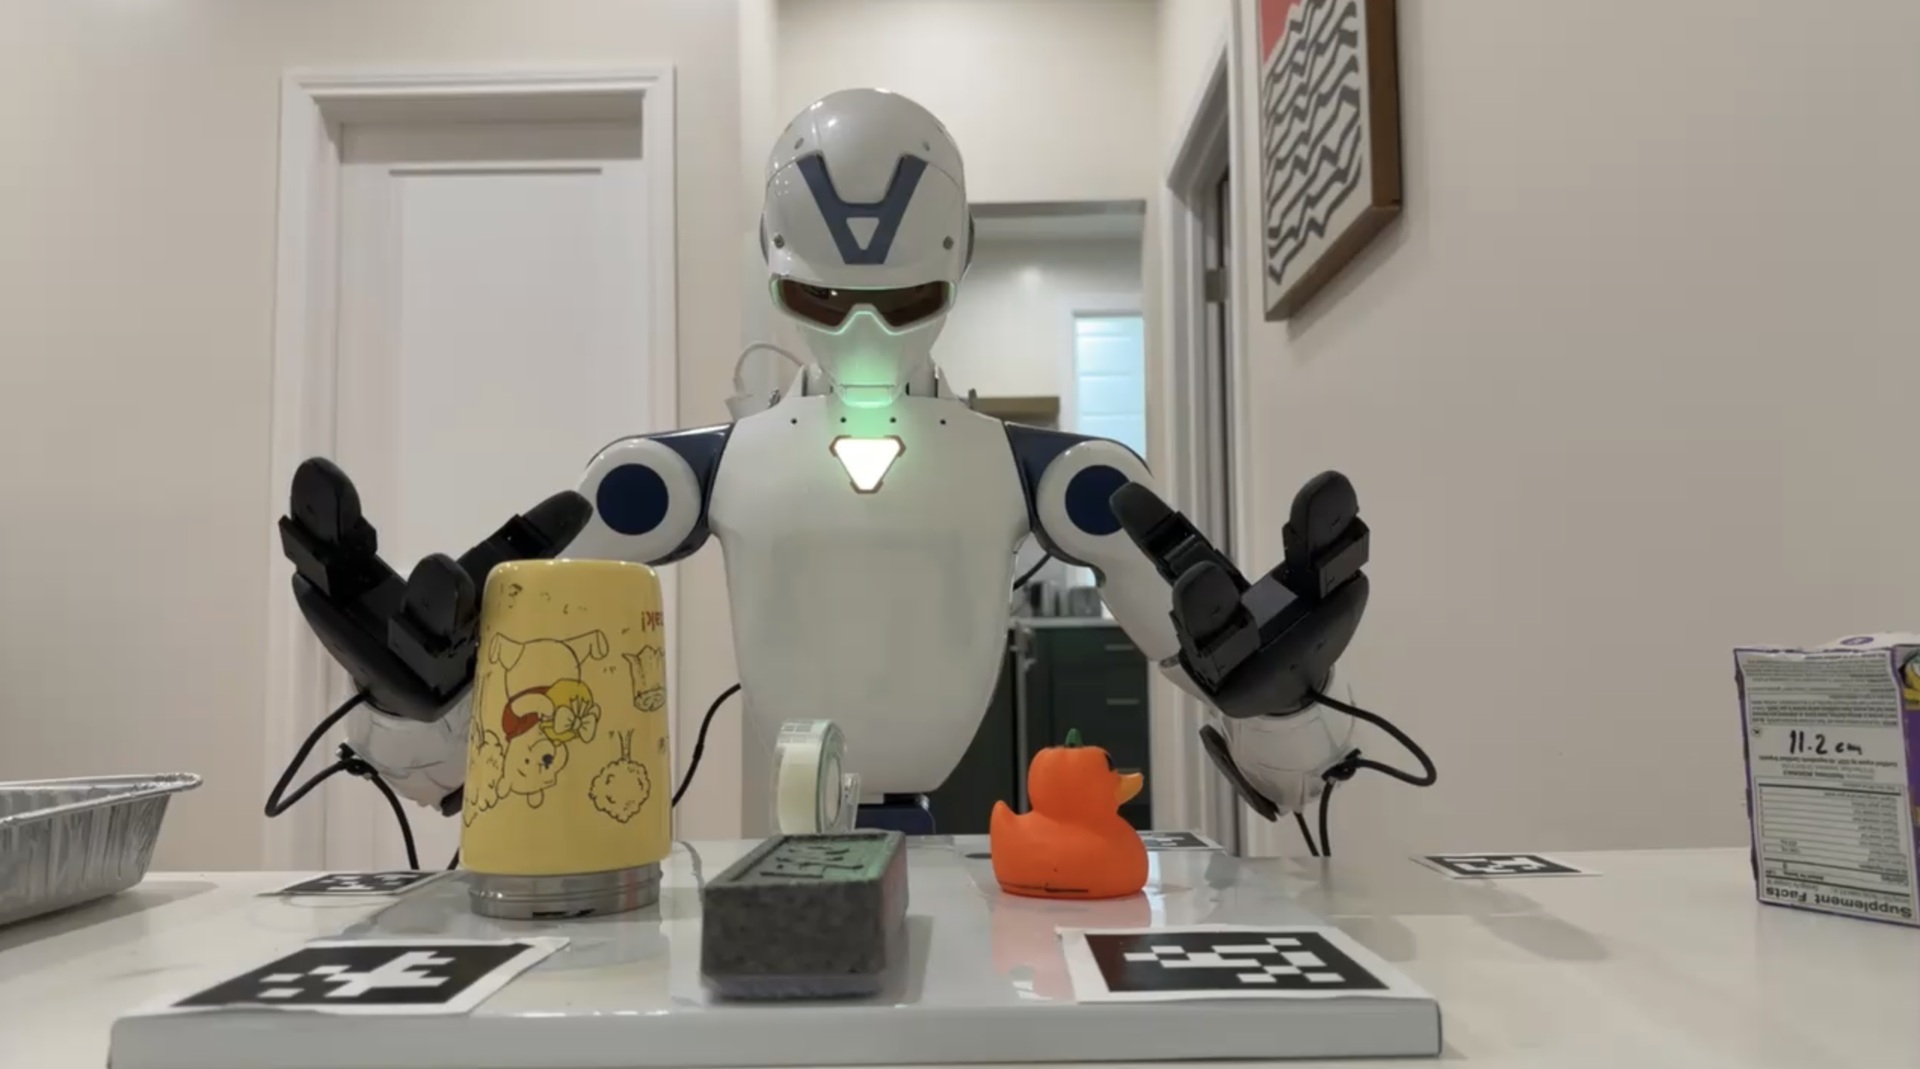
When “Done” Isn’t Done
Five models attempted a physical clearing and wiping task. Across 150 scored trials, none completed it. The partial results and completion claims tell a more revealing story.
Read article
The Coop journal
Notes on building, testing, and learning
from robots in the physical world.
Five models attempted a physical clearing and wiping task. Across 150 scored trials, none completed it. The partial results and completion claims tell a more revealing story.
Read article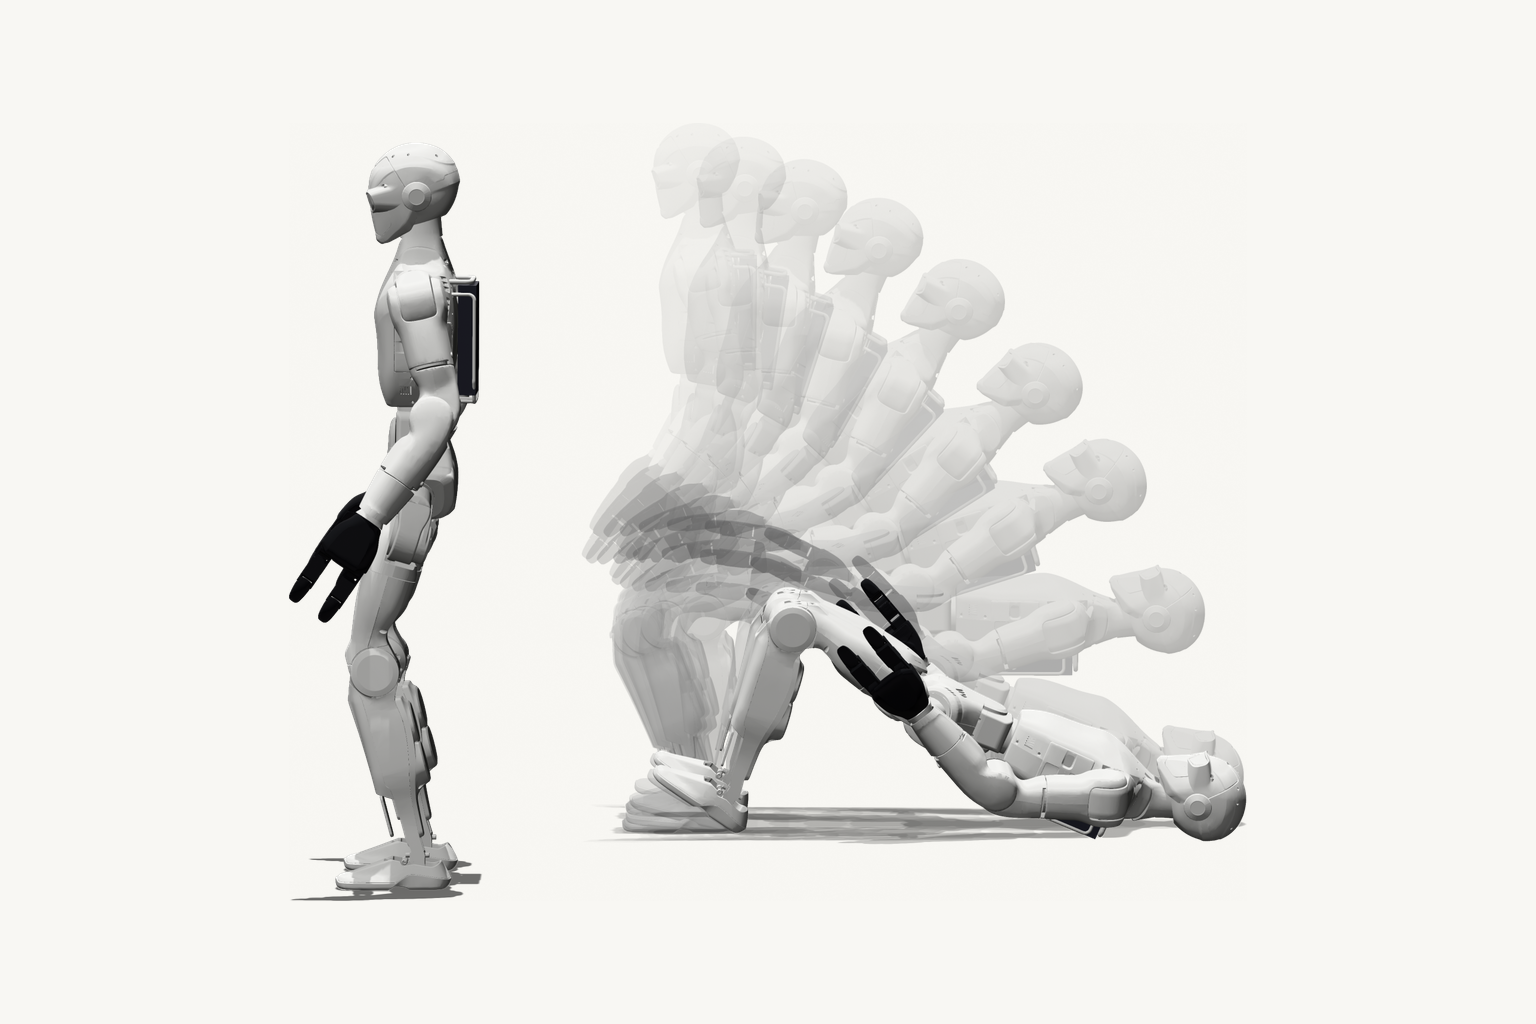
A high-level motor controller for the Unitree R1 did not exist. So we built it. Spur keeps the robot balanced while its arms and hands work, plans every motion before anything moves, and is now open source.
Read article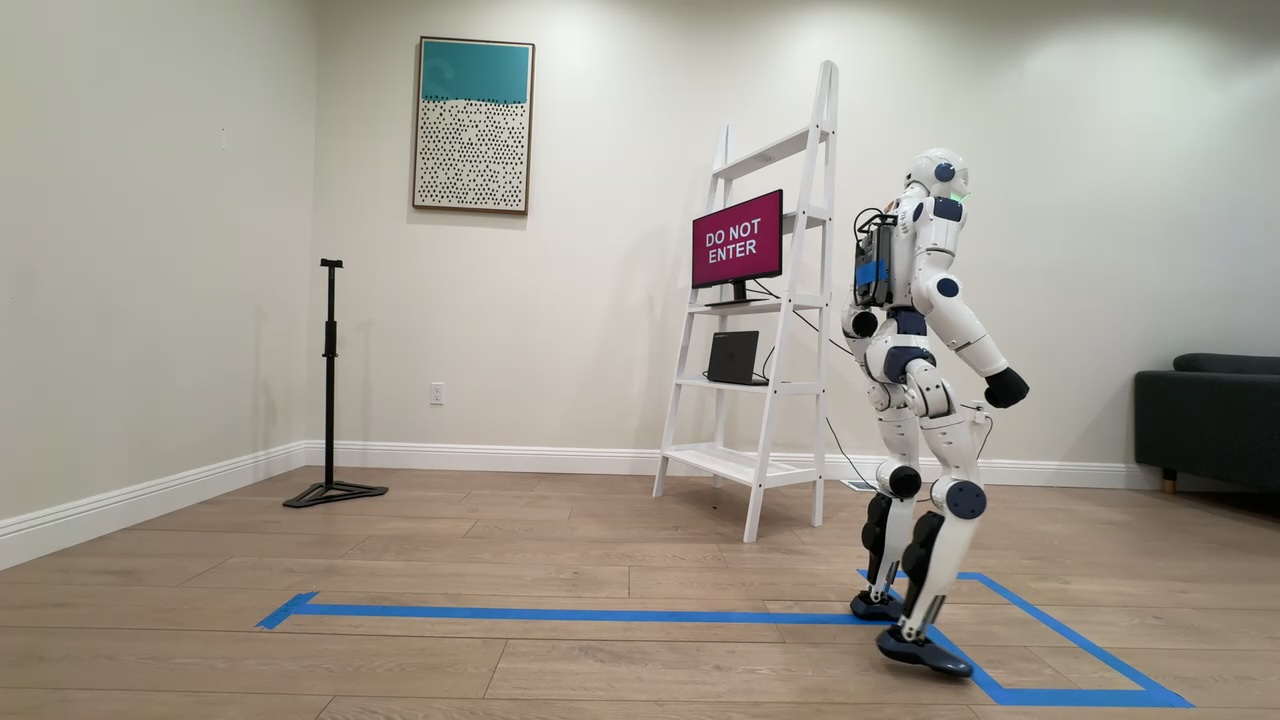
Four models, one humanoid, 220 trials. What a DO NOT ENTER sign revealed about instruction following, physical execution and reported success.
Read article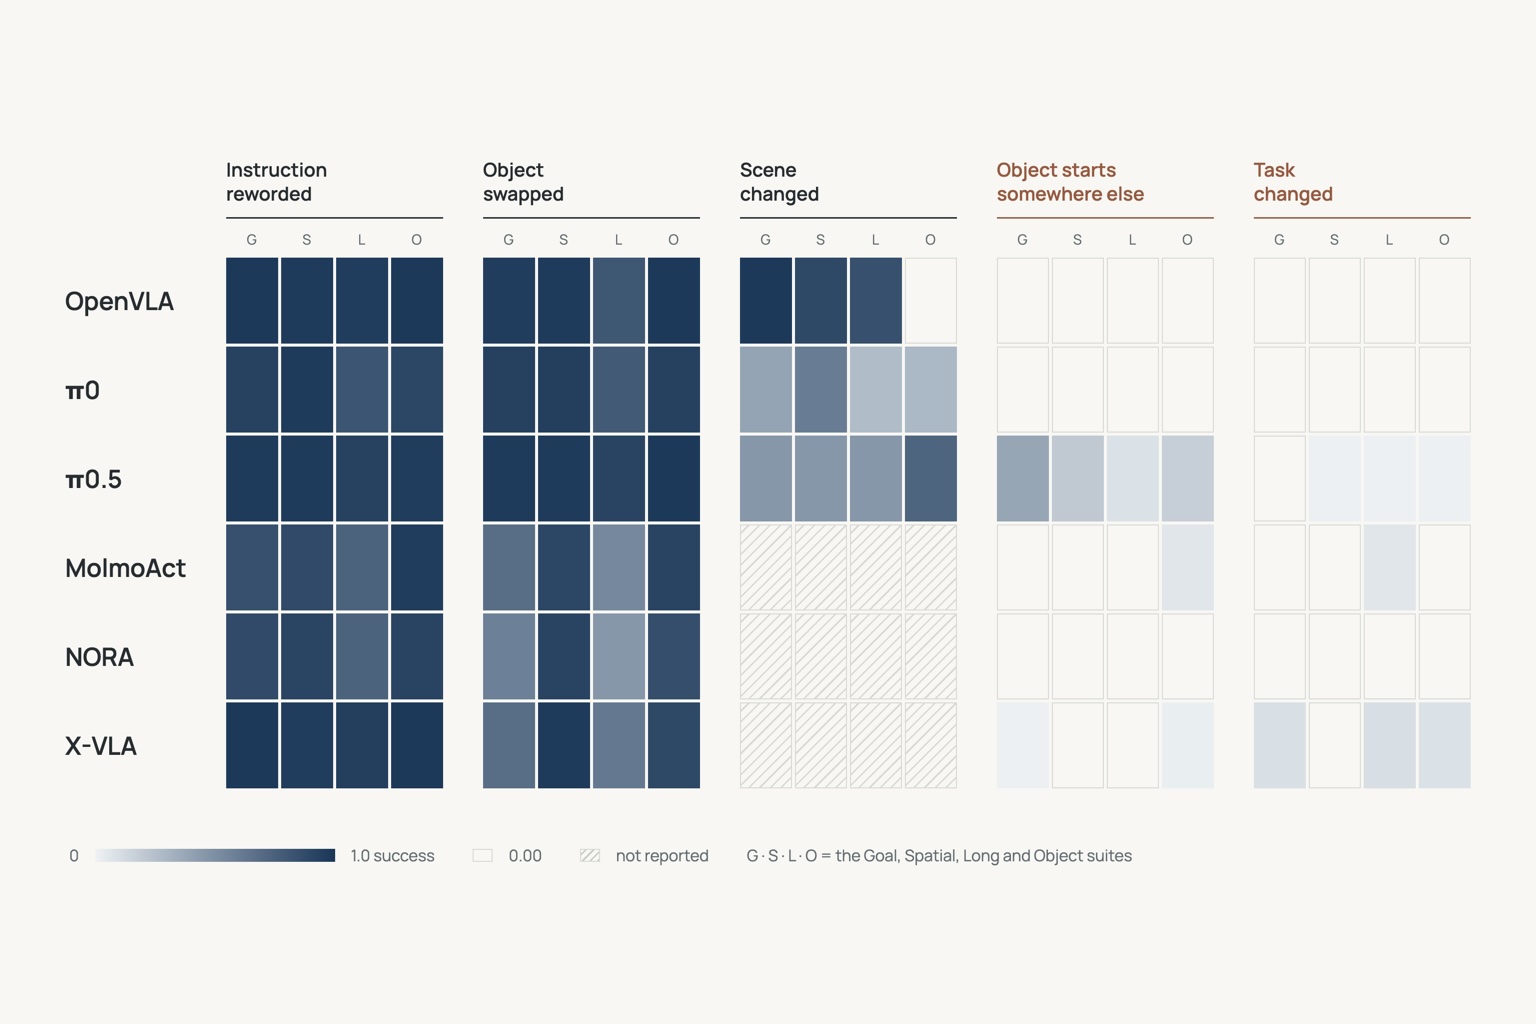
Why physical evaluation matters, where simulation falls short, and what benchmark saturation hides.
Read article
Independent, industry-specific benchmarks to help robot model developers understand what works, where it fails, and whether the next version is better.
Read article